HARMONIC JOINT MODULES
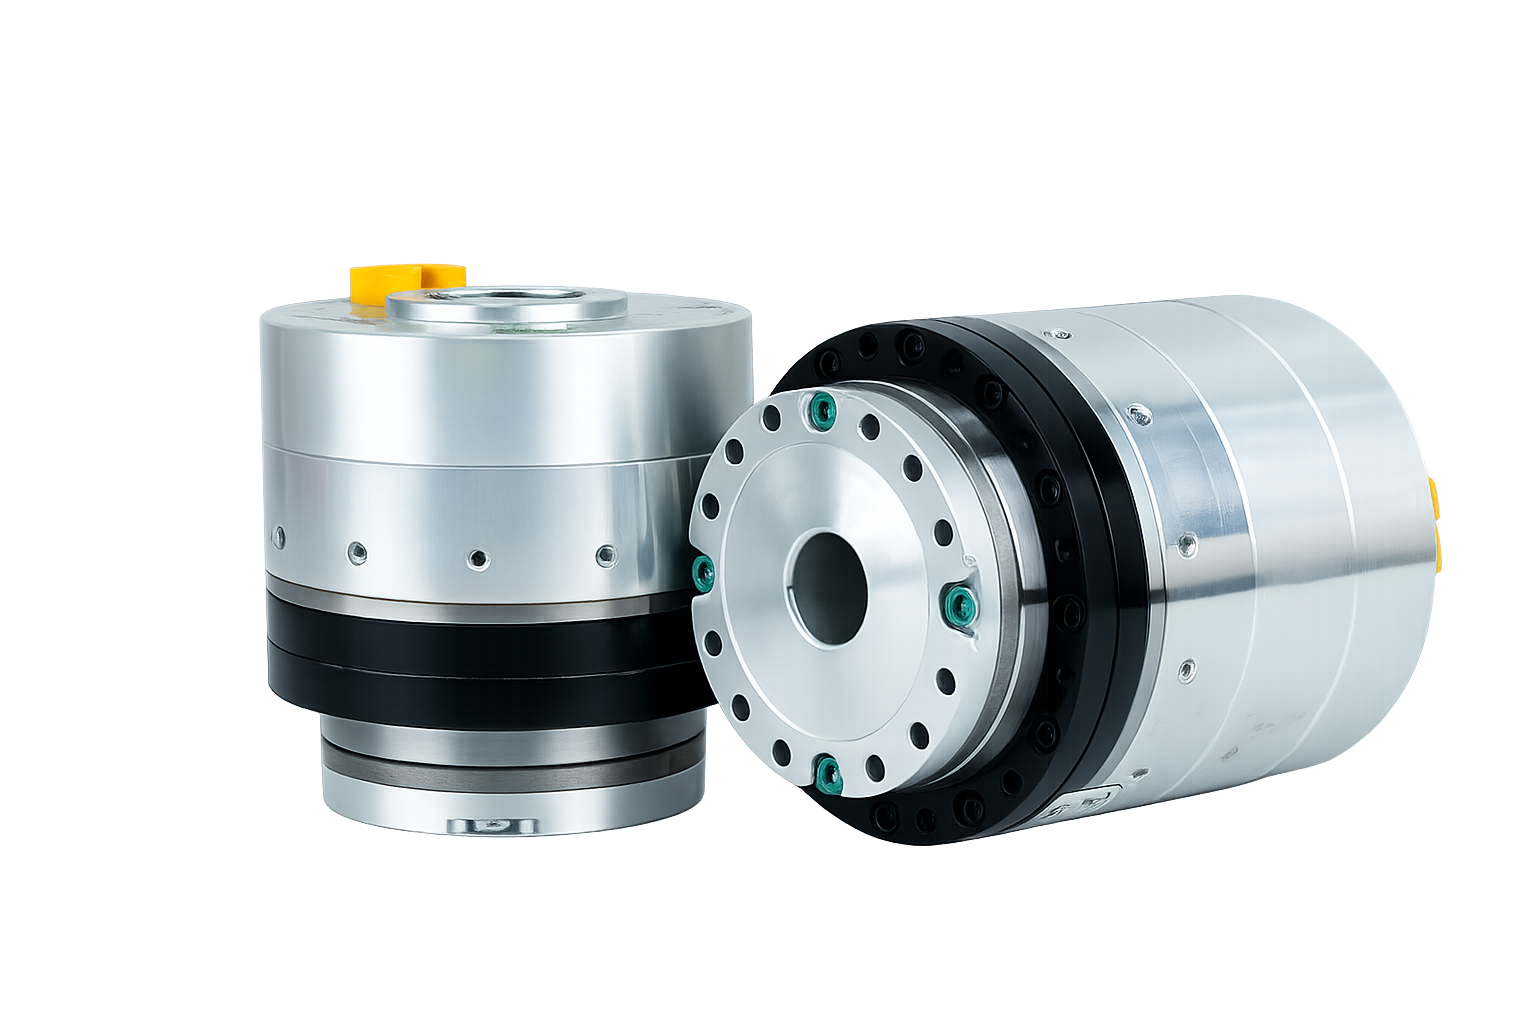
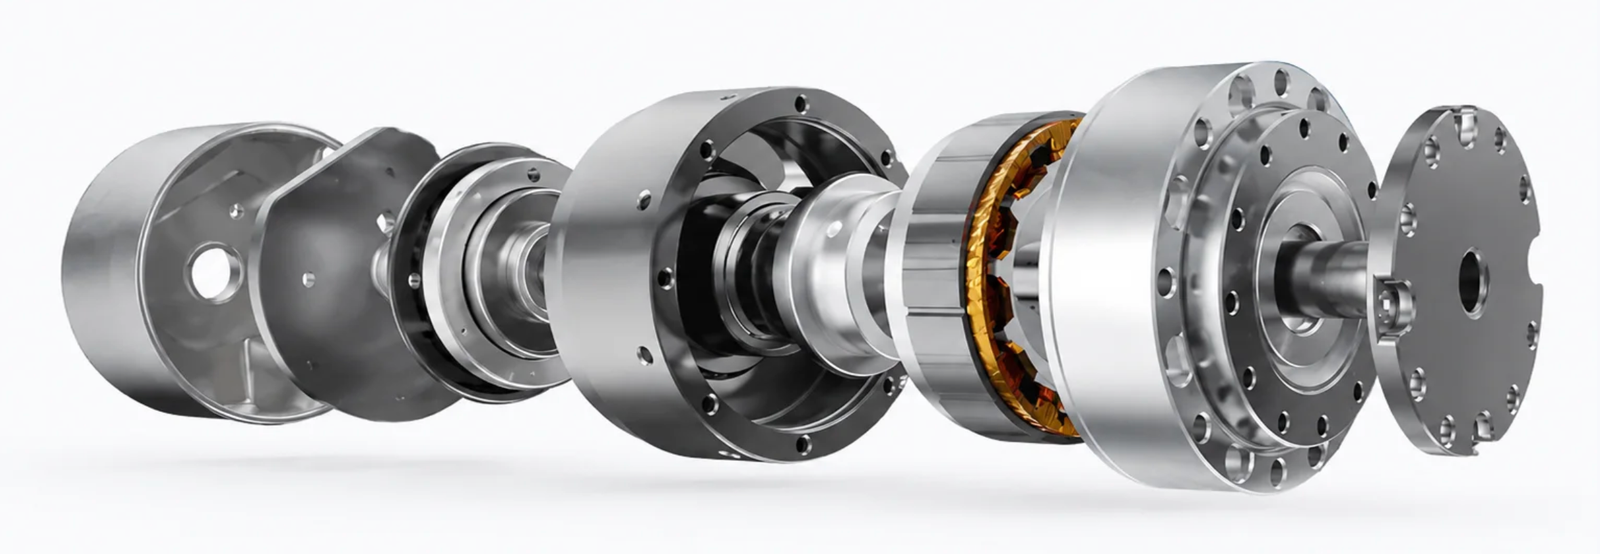
AHM harmonic joint actuators integrate precision harmonic reduction, motors, encoders and drive electronics into compact robotic joint modules. Available in multiple sizes and torque configurations, they support humanoid robots, collaborative robots and precision automation applications.
✓ Compact harmonic reduction platform
✓ Low-backlash positioning and precision feedback
✓ Optional brake, dual encoder, CAN and EtherCAT
MULTIPLE SIZES AND CONFIGURATIONS
HARMONIC JOINT MODULES
Explore ARTUS harmonic joint actuators by size and torque to find the right series for your robotic application.
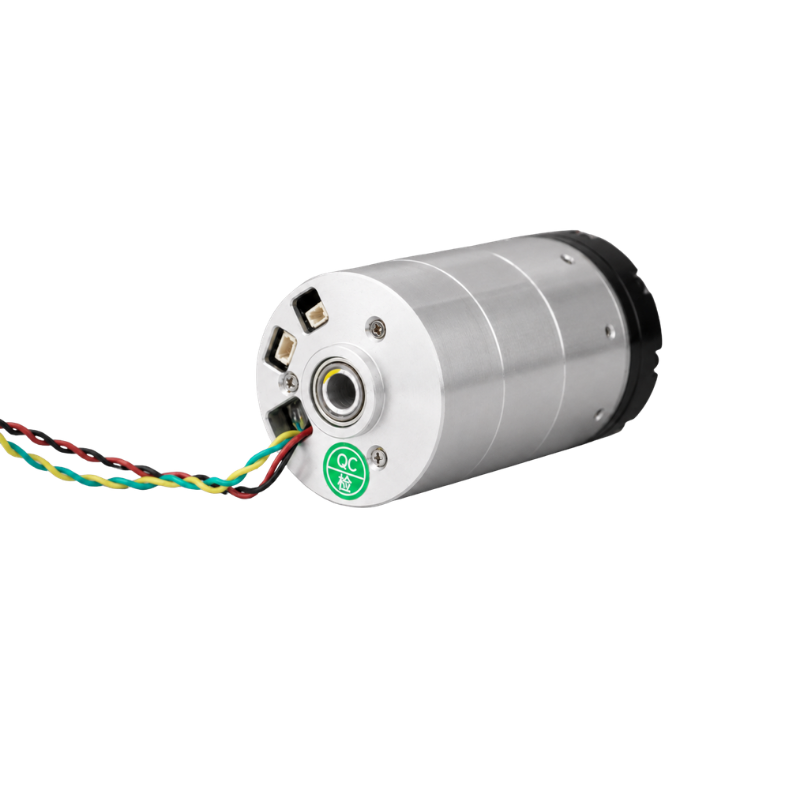
Ø40–60 mm · Peak Torque: 3.3–34 Nm
Compact harmonic joint actuators for space-constrained robotic applications.
Ø70–90 mm · Peak Torque: 23–108 Nm
Versatile harmonic joint actuators for robotic arms and humanoid joints.
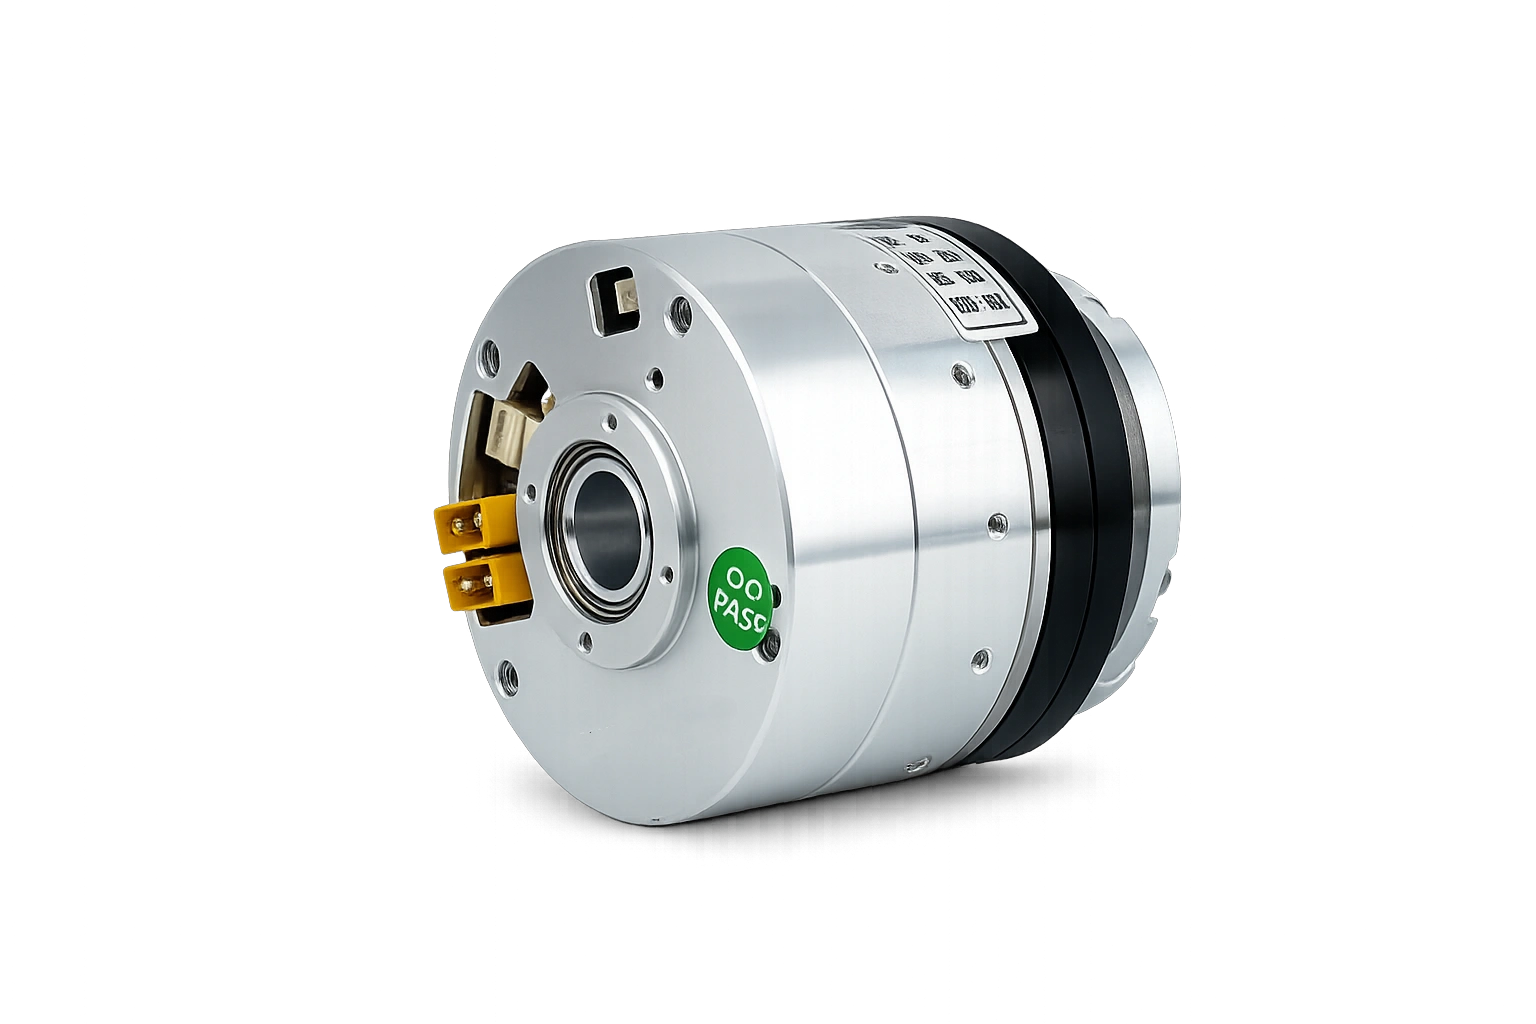
Ø97–120 mm · Peak Torque: 121–459 Nm
High-torque harmonic joint actuators for robotic arms and demanding joint applications.
Ø142–170 mm · Peak Torque: 267–800 Nm
High-capacity harmonic joint actuators for heavy-duty robotic applications.
Compare platforms by installation size and torque range, then expand a platform to view its complete model numbers and available reduction ratios.
| Series | Module Ø | Motor Ø | Ratios | Peak Torque | Rated Power | Weight | Communication | Configurations | ||||||||||||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| Compact | 40 mm | 30 mm | 51 / 101 | 3.3–4.8 Nm | 30 W | 0.19 kg | CAN / EtherCAT | |||||||||||||||||||
Ø40 mm platform configurations
The torque code is rounded for model identification. Use the exact value shown in the specification. | ||||||||||||||||||||||||||
| Compact | 52 mm | 40 mm | 51 / 101 | 8.3–11 Nm | 50 W | 0.32 kg | CAN / EtherCAT | |||||||||||||||||||
Ø52 mm platform configurations
| ||||||||||||||||||||||||||
| Compact | 60 mm | 50 mm | 51 / 81 / 101 | 23–34 Nm | 85 W | 0.45 kg | CAN / EtherCAT | |||||||||||||||||||
Ø60 mm platform configurations
| ||||||||||||||||||||||||||
| Mid-size | 70 mm | 50 mm | 51 / 81 / 101 | 23–34 Nm | 85 W | 0.66 kg | CAN / EtherCAT | |||||||||||||||||||
Ø70 mm platform with Ø50 mm motor
| ||||||||||||||||||||||||||
| Mid-size | 70 mm | 60 mm | 51 / 81 / 101 / 121 | 42–66 Nm | 230 W | 0.73 kg | CAN / EtherCAT | |||||||||||||||||||
Ø70 mm platform with Ø60 mm motor
| ||||||||||||||||||||||||||
| Mid-size | 80 mm | 60 mm | 51 / 81 / 101 / 121 | 42–66 Nm | 230 W | 1.03 kg | CAN / EtherCAT | |||||||||||||||||||
Ø80 mm platform with Ø60 mm motor
| ||||||||||||||||||||||||||
| Mid-size | 80 mm | 70 mm | 51 / 81 / 101 / 121 | 69–108 Nm | 340 W | 0.90 kg | CAN / EtherCAT | |||||||||||||||||||
Ø80 mm platform with Ø70 mm motor
| ||||||||||||||||||||||||||
| Mid-size | 90 mm | 70 mm | 51 / 81 / 101 / 121 | 69–108 Nm | 340 W | 1.27 kg | CAN / EtherCAT | |||||||||||||||||||
Ø90 mm platform configurations
| ||||||||||||||||||||||||||
| Large | 97 mm | 80 mm | 51 / 81 / 101 / 121 / 161 | 121–217 Nm | 450 W | 1.50 kg | CAN / EtherCAT | |||||||||||||||||||
Ø97 mm platform configurations
| ||||||||||||||||||||||||||
| Large | 110 mm | 80 mm | 51 / 81 / 101 / 121 / 161 | 121–217 Nm | 450 W | 2.06 kg | CAN / EtherCAT | |||||||||||||||||||
Ø110 mm platform configurations
| ||||||||||||||||||||||||||
| Large | 120 mm | 100 mm | 51 / 81 / 101 / 121 / 161 | 267–459 Nm | 720 W | 2.52 kg | CAN / EtherCAT | |||||||||||||||||||
Ø120 mm platform configurations
| ||||||||||||||||||||||||||
| Extra-large | 142 mm | 100 mm | 51 / 81 / 101 / 121 / 161 | 267–459 Nm | 720 W | 3.96 kg | CAN / EtherCAT | |||||||||||||||||||
Ø142 mm platform configurations
| ||||||||||||||||||||||||||
| Extra-large | 170 mm | 100 mm | 51 / 81 / 101 / 121 / 161 | 497–800 Nm | 650 W | 6.84 kg | CAN / EtherCAT | |||||||||||||||||||
Ø170 mm platform configurations
| ||||||||||||||||||||||||||
AHM = Actuated Harmonic Joint Module · 040 = 40 mm module outer diameter · 003 = 3 Nm peak torque class · R51 = 51:1 reduction ratio.
Select a platform by installation size and torque range, then choose the required reduction ratio to identify the complete AHM model. Contact ARTUS for detailed specifications, drawings and application verification.
Harmonic drive, motor, feedback, brake and control integrated into one compact joint module.
PRODUCTION CAPABILITY
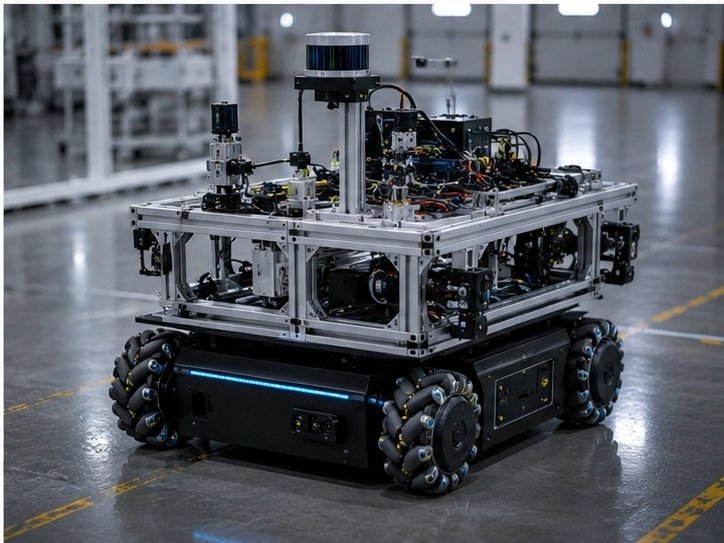
From prototype evaluation to volume production, ARTUS provides integrated engineering, manufacturing and delivery support for robotic joint module projects.
Annual Joint Module Capacity
Monthly Robot Production Support Capacity
Prototype Development
Pilot and Volume Production
QUALITY ASSURANCE
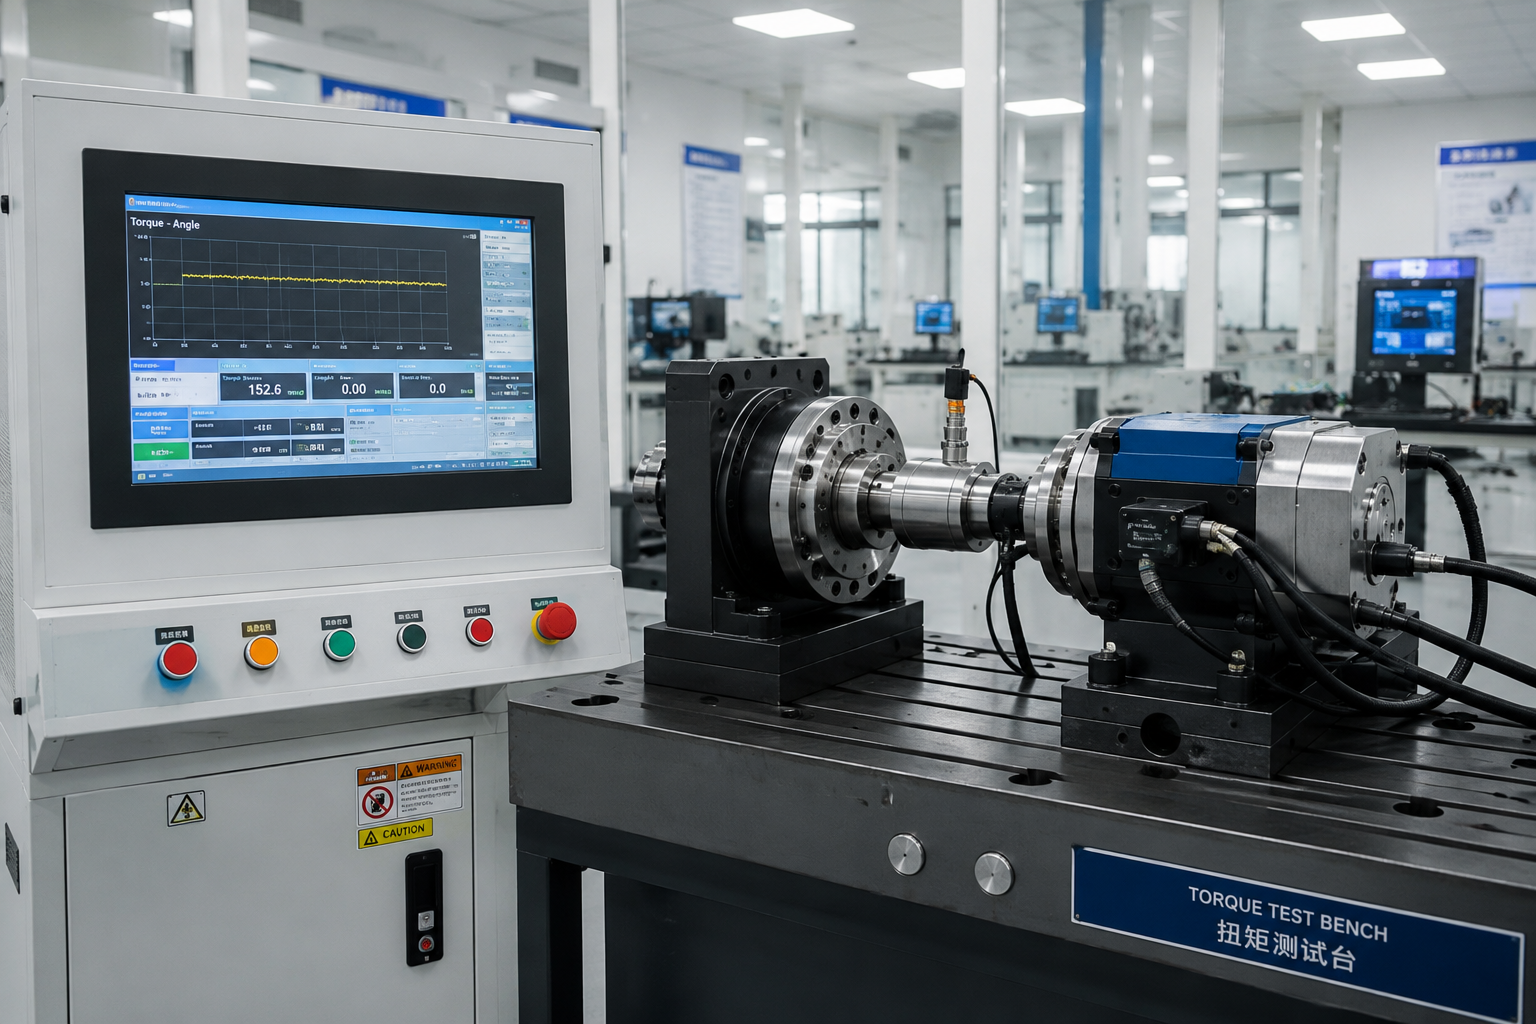
Our engineering and manufacturing process covers precision component production, module assembly, performance testing and production quality control. Each project is evaluated and verified according to the agreed operating conditions and technical requirements.
Share your target torque, reduction ratio, installation space, brake, encoder and communication requirements with our engineering team.
Request Technical Evaluation
Where intelligence takes form,
intent becomes motion.
Building 2, Jinhuanyu Science Park,
No.263 Changfeng Road, Guangming District, Shenzhen, Guangdong, China
© 2026 ARTUS Motion Systems Co., Ltd. All rights reserved.